Atlas Gets a Grip: Boston Dynamics Unveils Next-Gen Industrial Hand
Boston Dynamics has unveiled a new, highly capable hand for its Atlas robot, moving away from specialized grabbers toward a more versatile, robust design intended for mass-production environments.
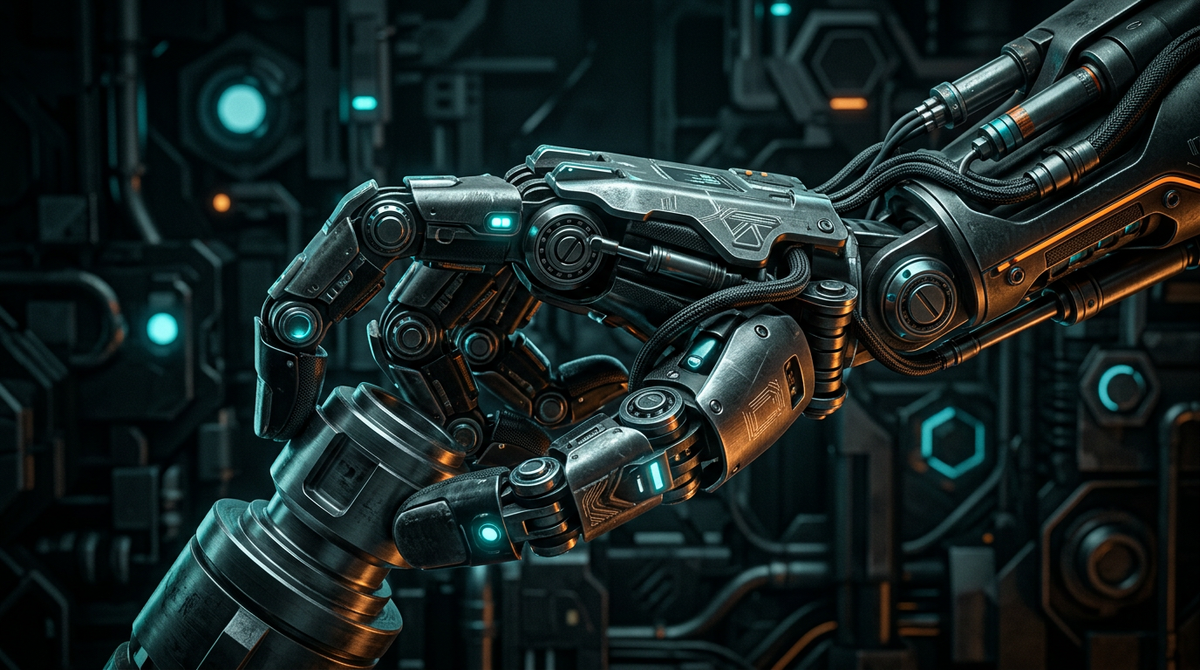
For years, the humanoid robot Atlas was known for its parkour and backflips, but its hands were often specialized "paws" or three-fingered grippers designed for specific tasks. With the latest announcement from Boston Dynamics, the focus has shifted toward a new, robust hand design that balances dexterity with the durability needed for industrial work. This new manipulator is a departure from previous human-like designs that were often too fragile for high-cycle factory environments.
The new hand is designed for "meaningful work"—the ability to grip varied objects, use tools, and interact with human-centric environments without the constant risk of mechanical failure. By reducing the complexity and increasing the toughness of the fingers, Boston Dynamics is signaling that the electric Atlas is moving toward a commercial release where reliability is as important as capability.
This development is part of a broader trend in robotics toward "generalized manipulation." As AI models for movement (like those from General Intuition) improve, the hardware must be capable of executing those complex trajectories. The new Atlas hand is a critical piece of the puzzle, providing the physical interface necessary for a humanoid to transition from a research curiosity to a viable worker in warehouses and manufacturing plants.
Source: IEEE Spectrum